Robotics and Embodied Intelligence
Comment
Stakeholder Type

Robotics and Embodied Intelligence

Robotics and Embodied Intelligence

Technologists have long dreamed of automating dull, dirty and dangerous jobs, freeing up humans for higher-value work. Advances in AI are at last opening up the prospect of smart, dextrous robots working alongside humans.1

Video

Will AI-powered robots become part of society?

    Robots have played a crucial role in industry for decades, with close to 4 million in operation today.2 However, getting them off factory floors and into the real world has proved challenging. Despite our ability to build machines that easily surpass humans in terms of power and precision, imbuing them with the intelligence and perceptual capabilities to carry out even the simplest human jobs has proven tougher than expected.

    Much of that is to do with the challenges of the physical environment. Traditionally, programming robots has involved creating detailed mathematical models of the robot and its environment, which are then used to deterministically control its actions. The approach is effective for well-defined tasks in predictable environments, such as assembling vehicles in an automotive factory. But this hand-engineered approach struggles with open-ended problems and the complexity encountered in environments that were not designed with robots in mind.

    AI, and in particular machine learning, promises a solution to this challenge. These techniques learn how to behave by training on data, which means they are not constrained by the designer’s preconceptions. This makes them more flexible and adaptable. There has already been significant success in using these approaches to improve robots’ visual perception and navigational capabilities. But recent advances are now making it possible to apply AI to more complex functions like sensorimotor control, planning and human interaction. In particular, breakthroughs in multimodal AI that can process a variety of different kinds of data are fuelling rapid improvements in robotic capabilities.3

    This gives the potential for a new generation of mobile robots to have the physical and even social intelligence to work seamlessly alongside us. Some of the most promising use-cases are in areas such as logistics, manufacturing, agriculture, food preparation and care work. Thanks to investor exuberance following recent AI advances, funding for these possible futures has been growing significantly.4 Embedding AI in physical bodies could also help models learn richer representations of the world, boosting their capabilities across domains.

    That said, robots still struggle with tasks that humans find effortless, such as folding clothes or navigating crowded spaces. Solving these challenges with AI will require vast amounts of real-world robotics data that is both difficult and costly to obtain, though advances in robot training simulators could help plug this gap. In the face of shrinking workforces and ageing populations around the world, proponents say the investment will be worth it. However, it is also important to anticipate the potential disruption to employment that could ensue if a significant number of robots start entering the workforce.5 The pace of change will require more agile approaches to governance that engages a wider range of stakeholders to adaptively respond to emerging ethical and social concerns.6

    KEY TAKEAWAYS

    The science-fiction dream of robots working seamlessly alongside us may be inching closer. Rapid advances in AI are transforming Robotic software, replacing hand-engineered, modular systems with massive models that can simultaneously solve perception control and planning. Caution is warranted, though, as these models are data- and power-hungry and their decision-making is hard to decipher. Breakthroughs in Robotic hardware will be needed to take full advantage of these new capabilities. Better tactile sensing could allow robots to take on dextrous tasks currently out of reach for them. But advances in both battery technology and energy-efficient chips will be necessary to boost mobile robot run times. A still bigger barrier though is AI’s insatiable thirst for Data, which is much harder to collect when it comes to robotics. Open data repositories are helping broaden access, and training models in simulations could provide a potential workaround to the shortage. Ensuring seamless Human-robot interaction will be more of a challenge. Large language models have opened up a promising new way to interface with robots. But imbuing them with social intelligence and the ability to predict human behaviours remains a distant goal.
    Topic:

    Anticipation Potential

    Robotics and Embodied Intelligence

    Sub-Fields:

    Robotic software
    Robotic hardware
    Data
    Human-robot interaction
    All sub-topics of Robotics and Embodied Intelligence have a high Anticipation Potential score. The main challenge in the field remains the expected major breakthroughs in Robotic hardware technology, which are believed to require another 15 years of research and development before they are realised. Human-robot interaction is a topic that will mature twice as fast and be highly transformative for society. Robotic software is the area that is believed to require the most international coordinated action.

    Anticipatory Impact:

    Three fundamental questions guide GESDA’s mission and drive its work: Who are we, as humans? How can we all live together? How can we ensure the well-being of humankind and the sustainable future of our planet? We asked researchers from the field to anticipate what impact future breakthroughs could have on each of these dimensions. This wheel summarises their opinions when considering each of these questions, with a higher score indicating high anticipated impact, and vice versa.

    • Anticipated impact on who we are as humans
    • Anticipated impact on how we will all live together
    • Anticipated impact on the well-being of humankind and sustainable future of our planet

    Robotic software

    Robotic control software is typically modular, featuring various subsystems that solve specific problems, including perception, navigation or motor control.7 Historically, these modules have been hand-coded, incorporating physical models of the robot’s hardware and environment, and decision trees telling it what to do in different situations.

    Future Horizons:

    ×××

    5-yearhorizon

    Robot locomotion is solved

    Rapid advances in VLAs see end-to-end approaches to robotic control replace modular architectures for the vast majority of applications. Mobile robots designed to operate in real-world environments become almost entirely AI-powered. Locomotion in diverse environments becomes a solved problem, greatly expanding application areas. LLMs make it possible for non-experts to direct robots through simple natural-language commands.

    10-yearhorizon

    Robots begin to exhibit embodied intelligence

    The most advanced robots start to exhibit sophisticated embodied intelligence, allowing them to undertake increasingly complex tasks and rapidly adapt to new challenges. Breakthroughs in interpretable AI as well as social acceptance of the technology allay some of the safety concerns around widespread robotic deployment.

    25-yearhorizon

    Self-conscious robots become lifelong learners

    As the deployment of robotic systems accelerates, autonomous embodied AI systems are capable of complex social interactions, empathy and moral reasoning. Breakthroughs in lifelong learning make it possible for robots to learn directly from their own experience rather than rely on generic pre-trained models.

    This can achieve impressive results. Boston Dynamic’s agile humanoid robots use this approach,8 for instance — but typically only for highly constrained tasks. Advances in AI mean these modules are increasingly being replaced by more flexible, learned models. Deep learning already powers “simultaneous localisation and mapping” (SLAM) in autonomous vehicles and drones,9 and helps sorting robots pick out and manipulate objects.10 Progress is being made in applying AI to locomotion and planning too.11

    Transformers – the algorithm behind large language models – promise to greatly expand AI’s use in robotics.12 LLMs themselves provide a more natural way to interface with robots via language.13 But transformers also power new multimodal models that can work with multiple data types.14,15 At the cutting edge, this is driving a shift from modular architectures to “end-to-end” models that simultaneously solve perception, control and planning.16,17 The latest generation of vision-language-action models (VLAs) are able to tackle a wide variety of tasks on a range of robotic hardware platforms.18,19 There is also growing interest in the use of diffusion models, which power AI image generators, for robot-motion planning.20

    The ability to draw correlations between different data sources, including language, vision and motion, could allow robots to develop a deeper understanding of the physical world and their place in it — something referred to as “embodied intelligence”.21,22,23 This could overcome AI’s “symbol grounding problem”,24 the ability to link the learned word or “symbol” of an object, such as “cup”, to the object’s real-world context. It could also allow AI to develop a sense of “self”,25,26 although a comprehensive theoretical understanding of consciousness remains a challenge.

    Moreover, current models are data- and power-hungry and incapable of learning on the fly. Their huge size means they must be stored on the cloud and communication delays between servers and the robotic hardware can be too long for fine-grained motor control. Their decision-making is also inscrutable, raising safety concerns. Breakthroughs in lifelong learning and interpretability will be crucial in the long run.27,28

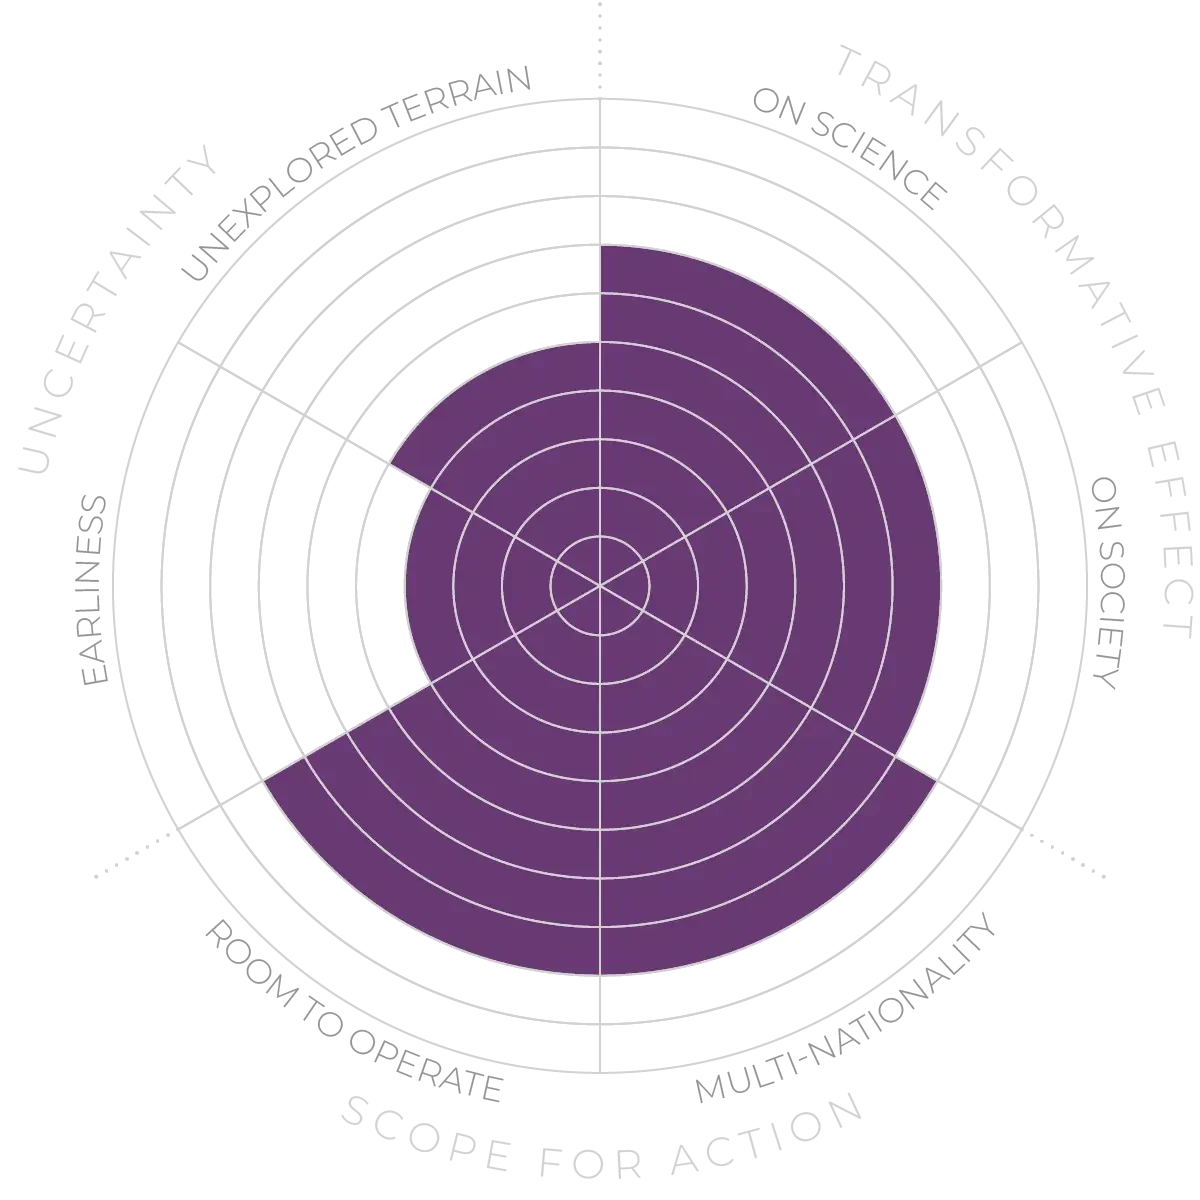
    Robotic software - Anticipation Scores

    The Anticipation Potential of a research field is determined by the capacity for impactful action in the present, considering possible future transformative breakthroughs in a field over a 25-year outlook. A field with a high Anticipation Potential, therefore, combines the potential range of future transformative possibilities engendered by a research area with a wide field of opportunities for action in the present. We asked researchers in the field to anticipate:

    1. The uncertainty related to future science breakthroughs in the field
    2. The transformative effect anticipated breakthroughs may have on research and society
    3. The scope for action in the present in relation to anticipated breakthroughs.

    This chart represents a summary of their responses to each of these elements, which when combined, provide the Anticipation Potential for the topic. See methodology for more information.

    Robotic hardware

    Software has long been the biggest bottleneck to robotics advances, but for the technology to reach its full potential, breakthroughs in hardware are also crucial.

    Future Horizons:

    ×××

    5-yearhorizon

    Robots become master manipulators

    More advanced manipulators and advances in tactile sensing allow robots to take on tasks requiring greater dexterity and so become commonplace in industries like retail, logistics, recycling and manufacturing. Economies of scale see the cost of robotic hardware fall significantly, further spurring adoption.

    10-yearhorizon

    Humanoid robots take over

    Breakthroughs in battery technology significantly increase run times of mobile robots. Humanoid robots become the dominant form factor due to the ease of integrating them into environments already adapted for humans. While still largely mechanical, robots feature an increasing number of soft components, particularly those deployed in safety-conscious areas such as medicine and care work.

    25-yearhorizon

    Robot bodies evolve

    Advances in hardware capabilities make it possible to realise the exotic designs dreamed up by evolutionary robotics algorithms, leading to a rapid diversification in robot body shapes. Robots look increasingly “organic” as they are now primarily composed of soft, active materials and powered by artificial muscles.

    Novel manipulator designs are allowing robots to carry out more delicate tasks than were previously possible.29 But they are still a long way from replicating the dexterity of the human hand. In particular, tactile sensing is still unable to provide the precise feedback crucial for handling soft and delicate objects or operating safely and socially alongside humans.30,31

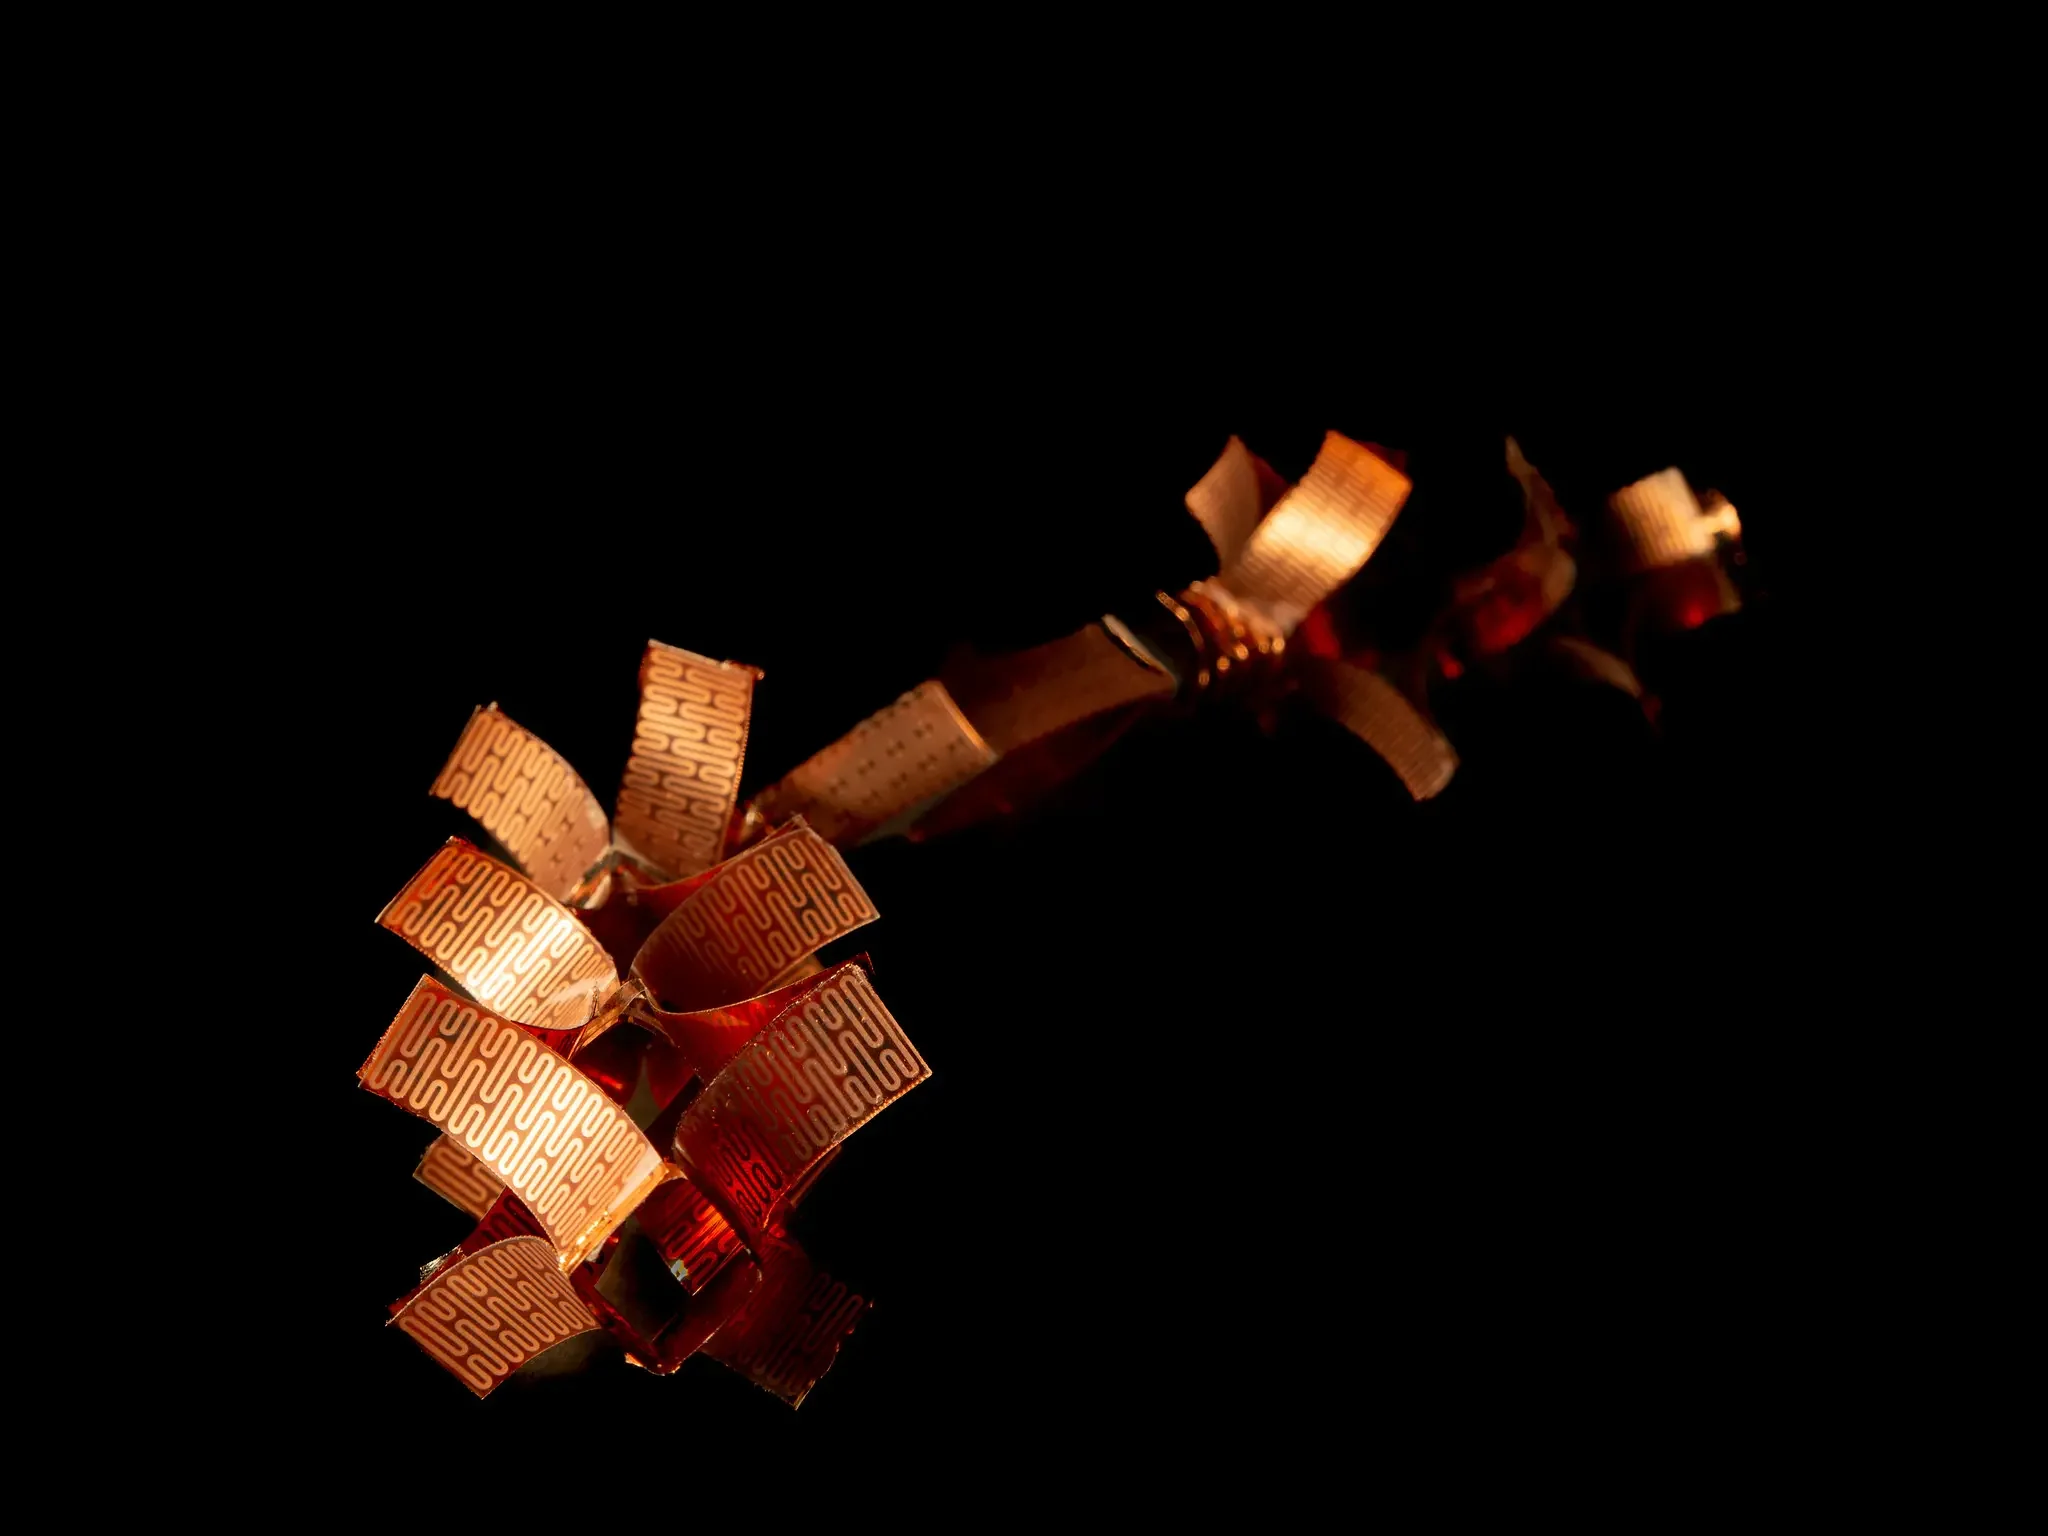
    However, advances are being made, and the latest robotics research platforms now include high-density tactile skins, improved fingertip sensors and biologically inspired cameras.32 The field of soft robotics could also provide solutions, in the form of active materials that can sense and actuate simultaneously.33 In particular, electronic skins that can provide multimodal sensory feedback are advancing rapidly.34,35 Artificial-muscle technology is a promising option,36,37,38 and the ability to rapidly transition between soft and rigid states could make it safer to deploy around humans than conventional hardware.

    There are more prosaic concerns, though. Both the computer hardware required to run AI and the mechatronics that enable robots to move are power-hungry, severely limiting run times for mobile robots. Better battery technology and more efficient chips will be crucial before robots can be more widely deployed. Robotic hardware is also expensive, though prices are falling.39 Cheap open-source robotics platforms in particular promise to democratise access to advanced hardware.40

    More broadly, there is often a lack of imagination when it comes robotic body plans. Most research is focussed on robotic arms, quadrupeds or humanoid robots, but the technology doesn’t need to be constrained to form factors already found in nature. Evolutionary robotics, which adapts robot designs to specific challenges,41 and robots that can dynamically alter their configuration hold considerable promise.42

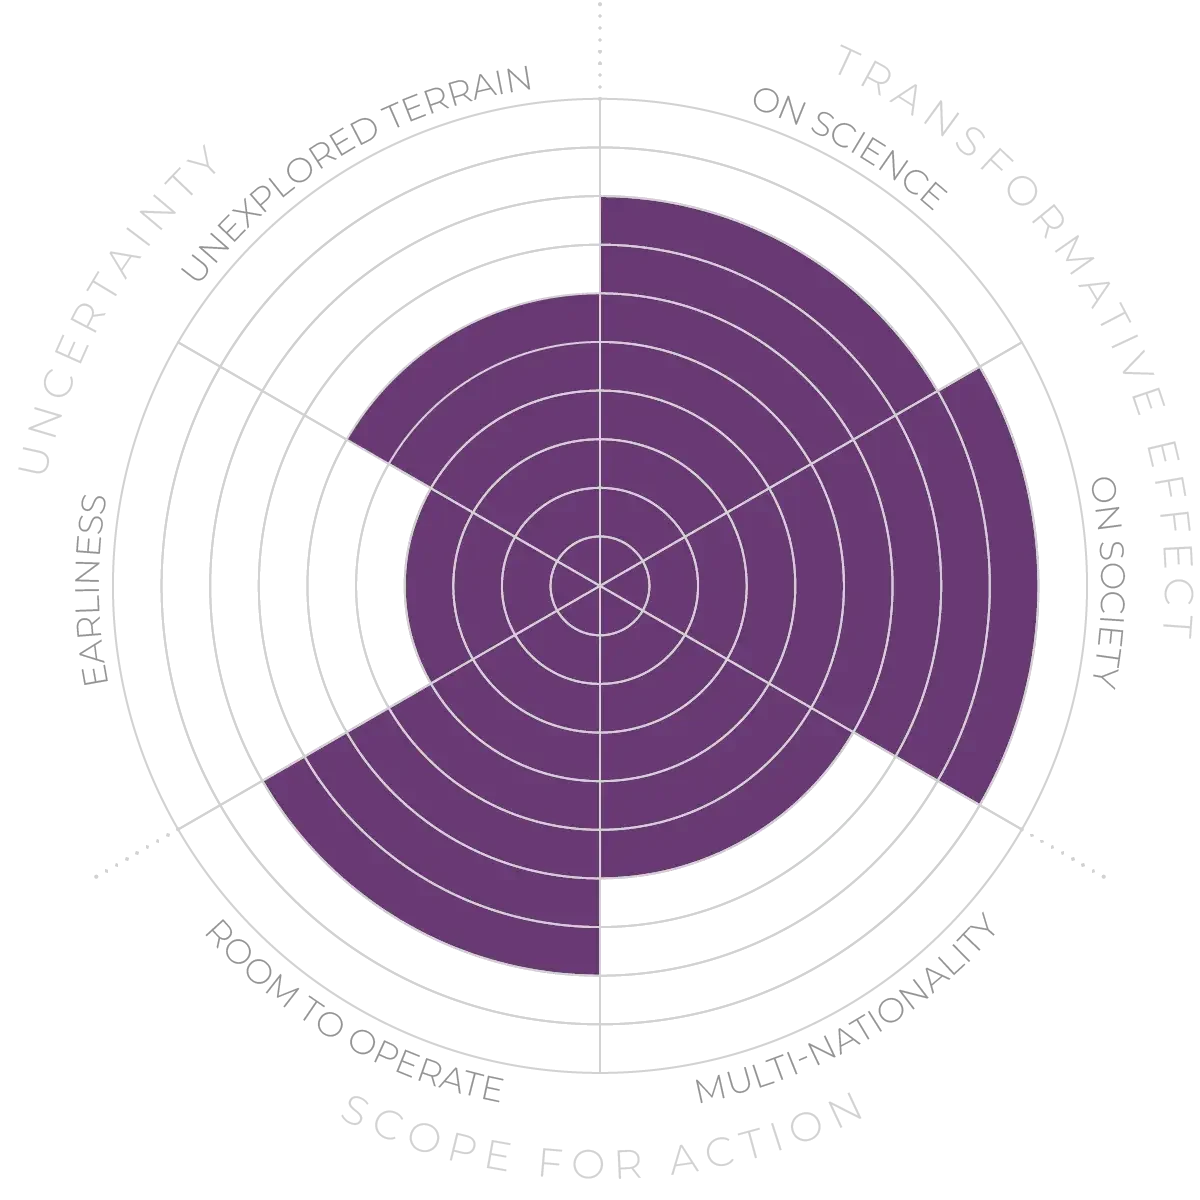
    Robotic hardware - Anticipation Scores

    The Anticipation Potential of a research field is determined by the capacity for impactful action in the present, considering possible future transformative breakthroughs in a field over a 25-year outlook. A field with a high Anticipation Potential, therefore, combines the potential range of future transformative possibilities engendered by a research area with a wide field of opportunities for action in the present. We asked researchers in the field to anticipate:

    1. The uncertainty related to future science breakthroughs in the field
    2. The transformative effect anticipated breakthroughs may have on research and society
    3. The scope for action in the present in relation to anticipated breakthroughs.

    This chart represents a summary of their responses to each of these elements, which when combined, provide the Anticipation Potential for the topic. See methodology for more information.

    Data

    Today’s state-of-the-art AI is incredibly data-hungry, which presents significant challenges for robotics applications. Most recent advances have come in domains like computer vision and natural-language processing, which can take advantage of the reams of image and text data on the internet. But real-world robotics data is much harder to come by, constraining the ability to train sophisticated models.

    Future Horizons:

    ×××

    5-yearhorizon

    Data remains a bottleneck

    Data remains a major bottleneck on robotic advances, but rapidly improving simulators, the increasing availability of open robotics data and more data-efficient training approaches help maintain progress. Ambitious governments start to set up national robotics centres with large numbers of robots that can carry out large-scale experiments and collect more data.

    10-yearhorizon

    A virtuous circle eases data woes

    Widespread deployment of robots leads to a steadily increasing deluge of robotics data. This helps accelerate advances, providing a further boost to deployment and creating a virtuous circle of progress. The robotics companies that build the devices are the greatest beneficiaries.

    25-yearhorizon

    The data crunch is over

    Data access ceases to be a significant problem due to the vast amounts being produced by widely deployed robots and more data-efficient training approaches. Data is no longer a differentiator, encouraging private companies to open up their datasets, providing a boost to academic research.

    Transformer-based AI presents both opportunities and fresh problems. Transfer learning — the ability to take a model trained on one kind of robot and deploy it on another — has been a long-standing challenge, as even small changes in environment or robot configuration can throw models off.43Transformers can train on data from multiple robots to create more general policies that work across varied embodiments and environments.44 However, training one of these models requires colossal amounts of data.

    One potential workaround involves training models in simulations before porting them over to real-world robots.45 However, many of the tasks planned for robots, such as handling soft and delicate objects, remain hard to simulate.46 Designing virtual worlds is complicated and expensive, requiring sustained effort from multidisciplinary teams.47 But high-fidelity simulators are becoming increasingly accessible,48,49 and there have been significant advances in techniques for transferring skills learned in virtual environments to real-world robots.50 Emerging “world models” that can generate physically realistic 3D environments from scratch could also become a powerful tool for training robots.51

    Pooling data-collection efforts will be crucial going forward, and there are promising efforts to create massive, open, robotics datasets.52,53 There will also be a growing focus on more data-efficient training approaches.54,55 Data shortages are likely to ease as more robots are deployed, though this will benefit the private companies that build them more than academic researchers.

    Data - Anticipation Scores

    The Anticipation Potential of a research field is determined by the capacity for impactful action in the present, considering possible future transformative breakthroughs in a field over a 25-year outlook. A field with a high Anticipation Potential, therefore, combines the potential range of future transformative possibilities engendered by a research area with a wide field of opportunities for action in the present. We asked researchers in the field to anticipate:

    1. The uncertainty related to future science breakthroughs in the field
    2. The transformative effect anticipated breakthroughs may have on research and society
    3. The scope for action in the present in relation to anticipated breakthroughs.

    This chart represents a summary of their responses to each of these elements, which when combined, provide the Anticipation Potential for the topic. See methodology for more information.

    Human-robot interaction

    Most industrial robots today are deliberately isolated from workers due to safety concerns. But ideally we would like robots to work seamlessly alongside, or even in coordination with, humans.

    Future Horizons:

    ×××

    5-yearhorizon

    Cobots enter the workplace

    Human-aware navigation is solved, making it possible for robots to be physically integrated into everyday life. LLMs allow people to have more complex and intuitive interactions with robots. Initial prototypes of robots with basic pain and empathy systems are developed. Collaborative robots become more common in the workplace, though only in the most routine jobs. Avatars — remote representations of real people — enable wider distribution of highly skilled services such as healthcare. However, the rapid introduction of robots into society requires more agile approaches to governance to respond to emerging challenges.

    10-yearhorizon

    Robots start to read human intention

    Autonomous robots have a rudimentary ability to understand human intentions and adapt to them. They also grasp basic social etiquette, such as turn-taking in conversations. Collaborative robots are able to take on more complex jobs when paired with a human expert who can guide the machine. There is increased adoption of empathetic robots in caregiving, education and companionship roles.

    25-yearhorizon

    Humans and robots adapt to each other

    Humans and robots are able to interact seamlessly and work side by side in most environments. Robots have developed sophisticated social intelligence and self-awareness, able to understand and respond to human emotions, while humans have adapted to the ways in which robotic “cognition” is different from the way humans think.

    At the most basic level, there has been progress on “human-aware” navigation algorithms that allow robots to safely occupy the same space as people.56 Collaborative robots, or “cobots”, are also capable of simple interactions like object handovers.57 But more sophisticated forms of human interaction are facilitated by deep reservoirs of implicit knowledge about social etiquette, and efforts to imbue this understanding and corresponding behaviour in machines remain rudimentary.58

    LLMs present a promising opportunity to chip away at these challenges by allowing humans to interface with robots through natural language.59There is even tentative evidence that they have limited ability to model the mental states of humans.60 The outputs of these models can be inconsistent and unreliable, though, which makes them unsafe to deploy in many real-world situations.

    Understanding how humans interact with robots, both physically and psychologically, and what their expectations of the technology are, is also crucial.61,62,63 Better understanding of how integrating robots into groups of humans impacts social dynamics is also needed.64 There is already evidence that the use of robots in social care can have unintended consequences that harm those they are supposed to help.65 And given the prevalence of bias in AI training data, robots could replicate existing patterns of discrimination.66,67 Developing socially adept robots which feel empathy, exhibit moral reasoning and act accordingly may also require them to be able to feel pain, raising many ethical questions.68 Establishing legal guidelines and frameworks to address the rights and responsibilities of autonomous robots will be required.

    Human-robot interaction - Anticipation Scores

    The Anticipation Potential of a research field is determined by the capacity for impactful action in the present, considering possible future transformative breakthroughs in a field over a 25-year outlook. A field with a high Anticipation Potential, therefore, combines the potential range of future transformative possibilities engendered by a research area with a wide field of opportunities for action in the present. We asked researchers in the field to anticipate:

    1. The uncertainty related to future science breakthroughs in the field
    2. The transformative effect anticipated breakthroughs may have on research and society
    3. The scope for action in the present in relation to anticipated breakthroughs.

    This chart represents a summary of their responses to each of these elements, which when combined, provide the Anticipation Potential for the topic. See methodology for more information.